kornia-slam
Library New
Real-time visual-inertial SLAM in Rust, built on kornia-rs.
- Downloads
- 8
- Dependents
- 0
- Stars
- 111
- Forks
- 24
- Contributors
- 6
- Commits
- 260
- Latest release
- 0.1.0 ·
About
Real-time visual-inertial SLAM in Rust, built on kornia-rs.
v0.1 — early release. The API will change between minor versions.
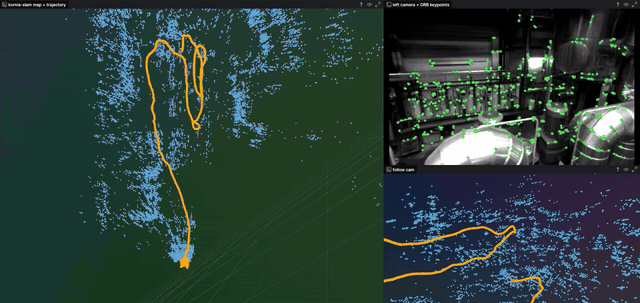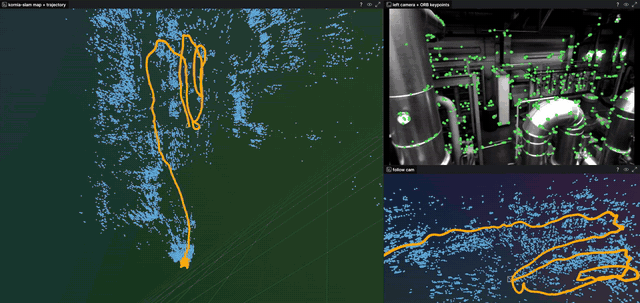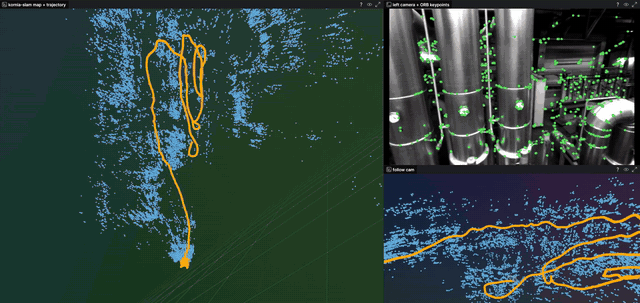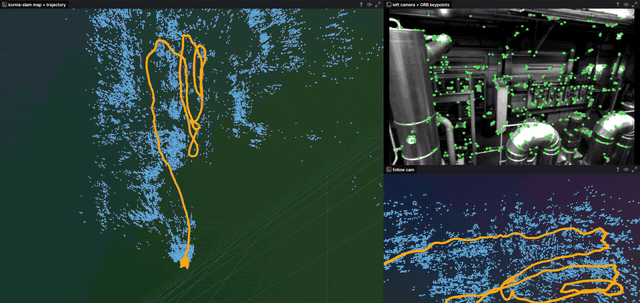 | 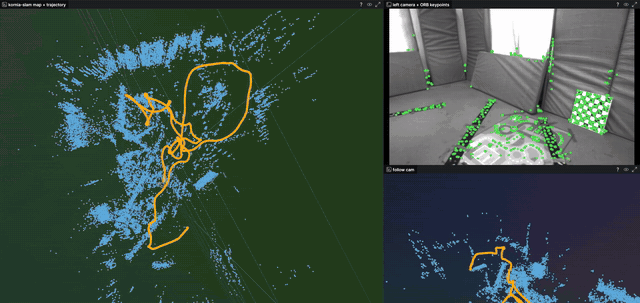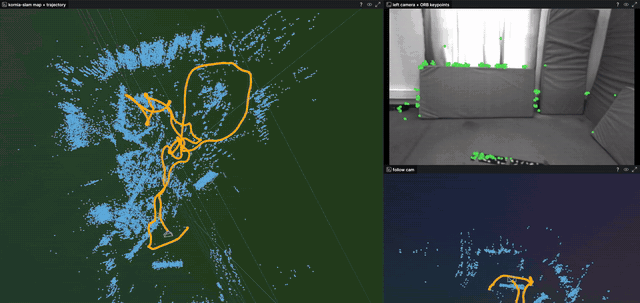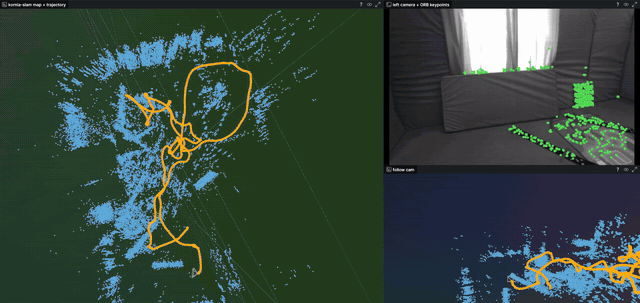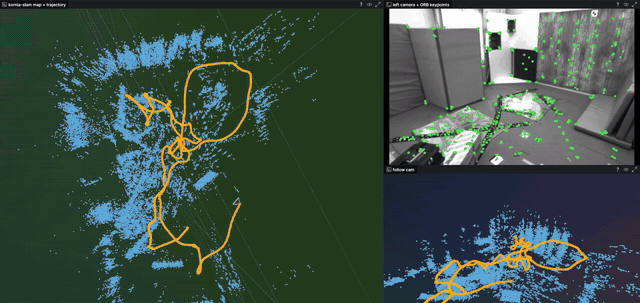 |
| EuRoC MH_01_easy | EuRoC V1_01_easy |
Stereo + IMU at 2× speed. Each shows the map and trajectory, the left camera with its ORB keypoints, and a follow view.
Features
- Monocular, stereo, and visual-inertial ORB SLAM
- Local bundle adjustment, including visual-inertial BA
- Place recognition (DBoW2) and loop closure with pose-graph optimization
- Sources: EuRoC, Hilti, MCAP, OAK-D, UVC webcams
- Terminal UI, Rerun streaming, ATE/RPE evaluation
See ROADMAP.md for what's next.
Install
Prebuilt binaries (v0.1.0)
Linux x86_64 and aarch64 builds need glibc 2.35+ (Ubuntu 22.04+, Jetson JetPack 6):
TARGET=x86_64-unknown-linux-gnu   # or aarch64-unknown-linux-gnu
NAME=kornia-slam-v0.1.0-$TARGET
curl -L --remote-name-all https://github.com/kornia/kornia-slam/releases/download/v0.1.0/$NAME.tar.gz{,.sha256}
sha256sum -c $NAME.tar.gz.sha256
tar -xzf $NAME.tar.gz

# stereo + IMU on an EuRoC sequence, with evaluation against ground truth
./$NAME/kornia-slam euroc --data /path/to/MH_01_easy --stereo --imu --evaluate
The archive holds the binary, README.md, CHANGELOG.md and LICENSE.
Read the full README
The v0.1.0 binary predates run files: it takes a source subcommand and flags
(kornia-slam --help, kornia-slam euroc --help) rather than the --config
run files described below. Global options go before the subcommand, e.g. loop
closing with the vocabulary from Quick start:
kornia-slam --vocab /path/to/ORBvoc.txt --apply-pgo euroc ….
It is built with the default features: Rerun streaming (--rerun-stream, which
needs the rerun 0.29.2 viewer on PATH, e.g. pip install rerun-sdk==0.29.2)
is in, live OAK-D and UVC cameras are not. Build from source with
--features oakd or --features uvc for those; OAK-D has extra prerequisites,
see apps/kornia-slam-app.
From source
The app needs Rust 1.91+ (the libraries 1.89+). Build and run with Cargo as in Quick start, or with Pixi, which provides the toolchain:
pixi run rust-run -- --config configs/euroc.ron
pixi run rust-lint
pixi run rust-test
Quick start
Download a EuRoC
sequence (ASL format) to data/euroc/MH_01_easy, or edit the data path in
the run file, then:
# monocular
cargo run --release -p kornia-slam-app -- --config configs/euroc.ron

# stereo + IMU with loop closing, with evaluation against ground truth
cargo run --release -p kornia-slam-app -- --config configs/euroc-stereo-imu-loop.ron --evaluate
Loop closing needs ORB-SLAM3's vocabulary: extract Vocabulary/ORBvoc.txt.tar.gz
from ORB-SLAM3 to weights/ORBvoc.txt.
A run file names the source and the system to run on it; see apps/kornia-slam-app.
More sources and options: apps/kornia-slam-app.
Library
A system configuration and the source's calibrated rig build a SlamSystem,
which then takes IMU samples and images as they arrive and returns poses. Feature extraction,
stereo matching and frame history are the system's; sources supply
synchronized, calibrated (and, for stereo, rectified) images.
use kornia_slam::{CameraSelection, SensorSelection, SlamSystem, SystemConfig};

let config = SystemConfig {
    sensors: SensorSelection { cameras: CameraSelection::Stereo, imu: true },
    ..SystemConfig::default()
};
let mut system = SlamSystem::build(config, rig)?; // rig: kornia_slam::SensorRig
for (idx, frame) in frames.enumerate() {
    system.process_imu(&frame.imu);
    let result = system.process_stereo(frame.timestamp_sec, &frame.left, &frame.right)?;
    println!("{idx}: {:?} {:?}", result.status, result.pose_world_to_cam);
}
With the serde feature, SystemConfig::from_ron_file reads the same settings
from a RON file, the system section of a run file.
Integrations
- Copper: stereo visual-inertial odometry as Copper tasks via cu-kornia-vio. See INTEGRATIONS.md for setup, graph wiring and timing requirements.
Development
With Pixi, which sets up the toolchain for you:
pixi run rust-lint           # fmt + clippy + check
pixi run rust-test           # workspace tests
pixi shell                   # drop into the environment
Or with a Rust toolchain (1.91+; the library crates alone need 1.89) installed yourself:
cargo fmt --all -- --check
cargo clippy --all-targets -- -D warnings
cargo test --workspace
Paper
Kornia-SLAM: An End-to-End Visual-Inertial SLAM System in Rust
Christie J. Purackal, Edgar Riba, Astik Srivastava.
Rust for Robotics workshop at IROS 2026 (preprint).
Paper (PDF) · Poster (PDF)
The paper's EuRoC results come from the August 2026 code, before v0.1.0. To cite kornia-slam, use GitHub's "Cite this repository" button, which reads CITATION.cff.
License
Apache-2.0
Compatibility
- Runs on
- GPU support unknown
What shows it
- no dependency or feature matches a backend row
- Native code
- None found
- No native code found
- Python bindings
- No Python binding crate found
- License
- Apache-2.0
Compare with similar projects
Order: strongest tier first, then most downloads, then name, with unmeasured values last. A library counts downloads over 30 days. An app counts binary downloads per release. An app with none counts its crate downloads over 30 days.
| Project | Downloads | Dependents | Stars | Latest release | Runs on (GPU) | Native code | License |
|---|---|---|---|---|---|---|---|
|
Real-time visual-inertial SLAM in Rust, built on kornia-rs. |
8 downloads over 30 days | 0 | 111 | 0.1.0 | GPU support unknown | No native code found | Apache-2.0 |
|
opencv-rust Featured
Rust bindings for OpenCV |
262,425 downloads over 30 days | 96 | 2,500 | 0.101.1 | GPU support unknown | Build uses a native toolchain: cc, pkg-config, vcpkg | MIT |
|
ML-powered manga translator, written in Rust. |
6,338 binary downloads per release | Not applicable | 6,620 | Not measured | Not measured | Apache-2.0 | |
|
inference Listed
Ultralytics YOLO inference library and CLI for Rust |
2,609 downloads over 30 days | 1 | 217 | 0.0.56 | CUDA, WebGPU, ROCm | Binds native code: ort-sys, ffmpeg-sys-next (feature video), openvino-sys (feature intel) | AGPL-3.0 |
|
kornia-rs Listed
Low-level computer vision library in Rust |
2,294 downloads over 30 days | 6 | 751 | 0.1.5 | CUDA | Binds native code: glib-sys (feature gstreamer), gobject-sys (feature gstreamer), gstreamer-app-sys (feature gstreamer), gstreamer-base-sys (feature gstreamer), gstreamer-sys (feature gstreamer) and 1 more | Apache-2.0 |
|
Visual odometry in Rust (vors) |
0 downloads over 30 days | 0 | 61 | 0.1.0 | GPU support unknown | No native code found | MPL-2.0 |
Why NewIts first release on 27 Sep 2026 is under 180 days old.
The check tests the Featured gates once the first release passes this age limit.
What else the check found
- The last activity is on 29 Oct 2026, 11 days ago. The rules expect an update within 365 days. Dormancy rule
Exact rules: New. The check on applied thresholds version 9.
Every rule outcome, as the check records it
expected-interval: version 0.1.0 base 80, capped at 1 releases = 50, raised to the 365-day floor: E = 365 daysdormancy: last activity 2026-10-29, 11 days ago, E = 365: activenew: new: first release 2026-09-27 is under 180 days old
Crates2 crates
- kornia-slam Primary
- kornia-sensors
Measurements and sources
Each signal row shows the raw value, its source and the fetch date. The Sources list gathers every distinct source on this page. Movement needs more history.
Sources6 sources
- Description: the crates.io description
- crates.io database dump, fetched
- RustSec advisory database, fetched
- GitHub repository, fetched
- crates.io package, fetched
- GitHub contributors, fetched
Adoption0 active dependents, 0 new dependents in 365 days1 not measured
| Signal | Value | Source | Fetched | Counts |
|---|---|---|---|---|
| Active dependents | 0 | crates.io database dump | Yes | |
| New dependents (365 days) | 0 | crates.io database dump | Yes | |
| Peak active dependents | 0 | crates.io database dump | Yes | |
| Active dependents as a share of the peak | 1 | crates.io database dump | Yes | |
| Binary downloads per release | Not measured | Yes |
MaintenanceLatest human commit: 11 days ago3 not measured
| Signal | Value | Source | Fetched | Counts |
|---|---|---|---|---|
| Latest human commit | 2026-10-29 | GitHub repository | Yes | |
| Latest release | 2026-09-27 | crates.io database dump | Yes | |
| First release | 2026-09-27 | crates.io database dump | Yes | |
| Latest version | 0.1.0 | crates.io database dump | Yes | |
| Days the oldest outside issue waits for a reply | 36 | GitHub repository | Yes | |
| Maintainer replies over 365 days | 71 | GitHub repository | Yes | |
| Repository archived | false | GitHub repository | Yes | |
| Repository gone | false | GitHub repository | Yes | |
| Release commit or manifest in the repo | true | crates.io package | Yes | |
| Published docs | true | crates.io database dump | Yes | |
| Latest release fails cargo check | Not measured | Yes | ||
| Build check date | Not measured | Yes | ||
| Build check toolchain | Not measured | Yes |
SecurityUnpatched vulnerabilities: none
| Signal | Value | Source | Fetched | Counts |
|---|---|---|---|---|
| Unpatched vulnerabilities past the grace window | none | RustSec advisory database | Yes | |
| RustSec unmaintained advisory | none | RustSec advisory database | Yes | |
| Deprecation notice | none | crates.io database dump | Yes | |
| Deprecated requirement | none | crates.io database dump | Yes |
Distribution1 releases, 8 downloads over 30 days5 not measured
| Signal | Value | Source | Fetched | Counts |
|---|---|---|---|---|
| Releases | 1 | crates.io database dump | Yes | |
| Downloads over 30 days | 8 | crates.io database dump | Yes | |
| Binary downloads over the last 3 releases | Not measured | Yes | ||
| Homebrew installs on request over 365 days | Not measured | Yes | ||
| Repology repository families | Not measured | Yes | ||
| Docker pull growth over 90 days | Not measured | Yes | ||
| Docker pulls at the growth baseline | Not measured | Yes | ||
| Every version a prerelease | false | crates.io database dump | Yes | |
| Every version 0.0.x | false | crates.io database dump | Yes | |
| Every version yanked | false | crates.io database dump | Yes | |
| Crate deleted from crates.io | false | crates.io database dump | Yes |
Repository111 stars, 24 forks, 6 contributors, 260 commits. Stars alone never qualify a project.
| Signal | Value | Source | Fetched | Counts |
|---|---|---|---|---|
| GitHub stars | 111 | GitHub repository | Yes — one part of the repository route | |
| GitHub forks | 24 | GitHub repository | Yes — one part of the repository route | |
| Contributors with a GitHub account | 6 | GitHub contributors | Yes — one part of the repository route | |
| Commits on the default branch | 260 | GitHub repository | No | |
| Repository's main crate left out of the entry | none | crates.io database dump | Yes |
Facts that never count
| Signal | Value | Source | Fetched | Counts |
|---|---|---|---|---|
| License | Apache-2.0 | crates.io database dump | No | |
| Runs on, from listed crates and their direct dependencies | GPU support unknown | crates.io database dump | No | |
| What shows each backend | no dependency or feature matches a backend row | crates.io database dump | No | |
| Native code, from listed crates and their dependencies | No native code found | crates.io database dump | No | |
| Python bindings, from direct dependencies of listed crates | No Python binding crate found | crates.io database dump | No | |
| Crates that depend on a listed crate directly | 0 | crates.io database dump | No |
Corrections and review history
No correction applies to this entry.
Judgments
A judgment enters only through an approved issue and a merged pull request.
No judgment applies to this entry.